Acquire
Dream Catcher
An arm that teaches by feel, a glove that records touch, a studio for capture and review, and Lucid for bilateral control.
Live demo available
Explore Dream Catcher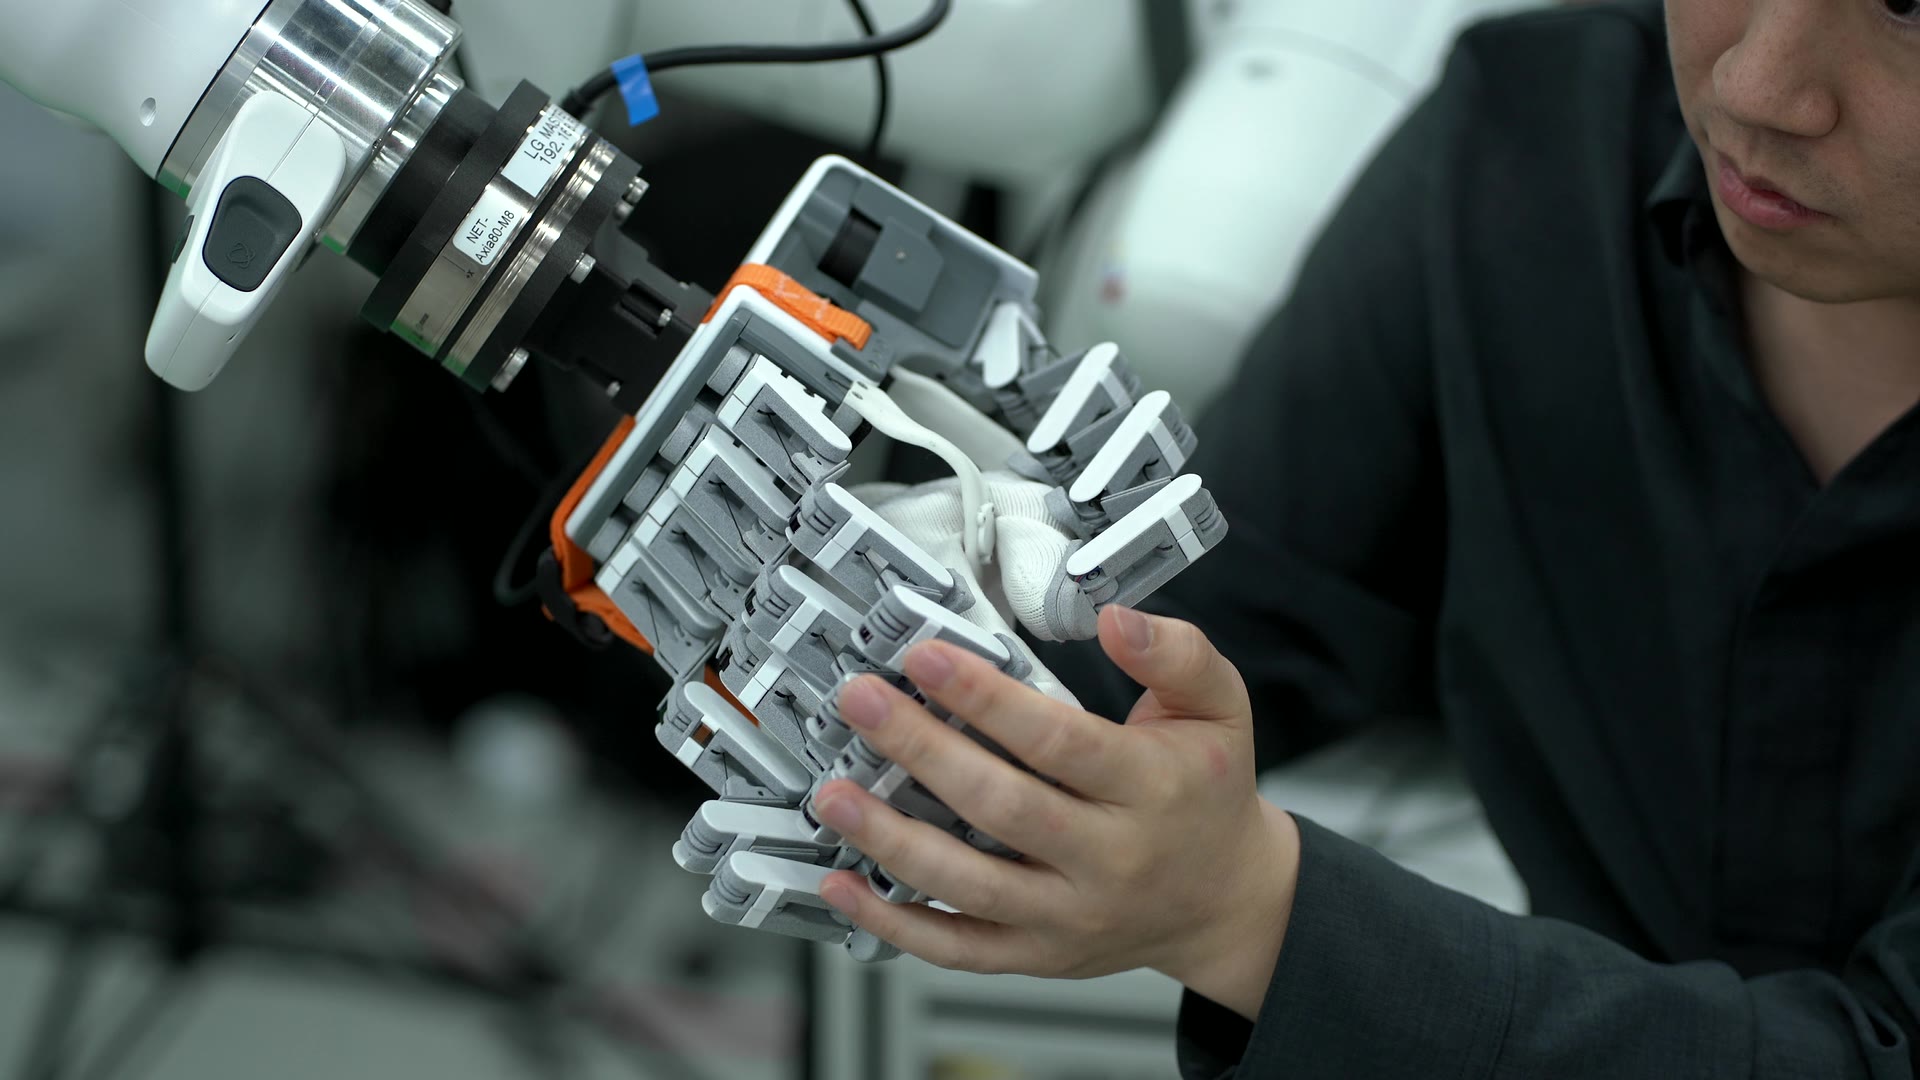
Wrist force
1.20N
Six-axis force and torqueVisualized
Axes
Pushing, fastening, pressing into place. That work runs on force and touch, not on sight.
We record the force skilled workers actually feel, from the arm to the fingertip, and teach it to robots.
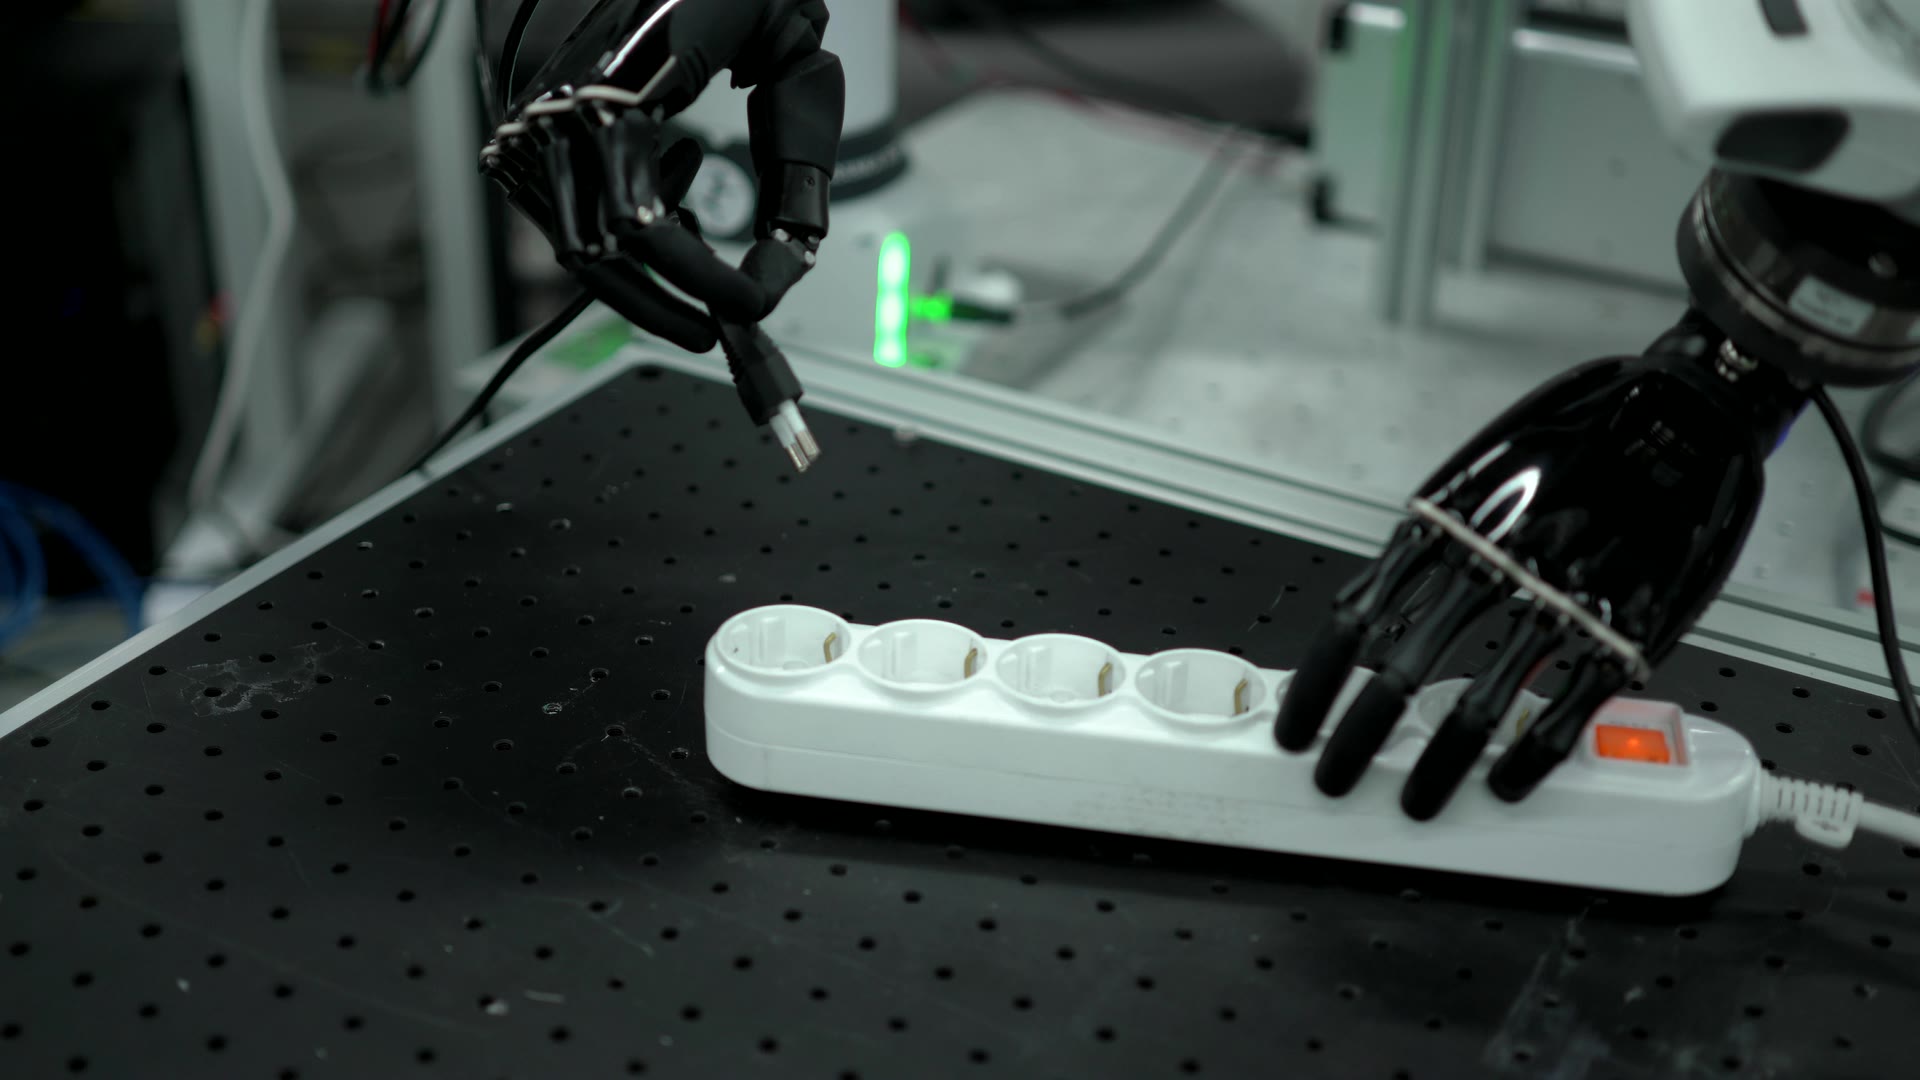
Drag the plug into the socket. It gets heavier as it goes in.
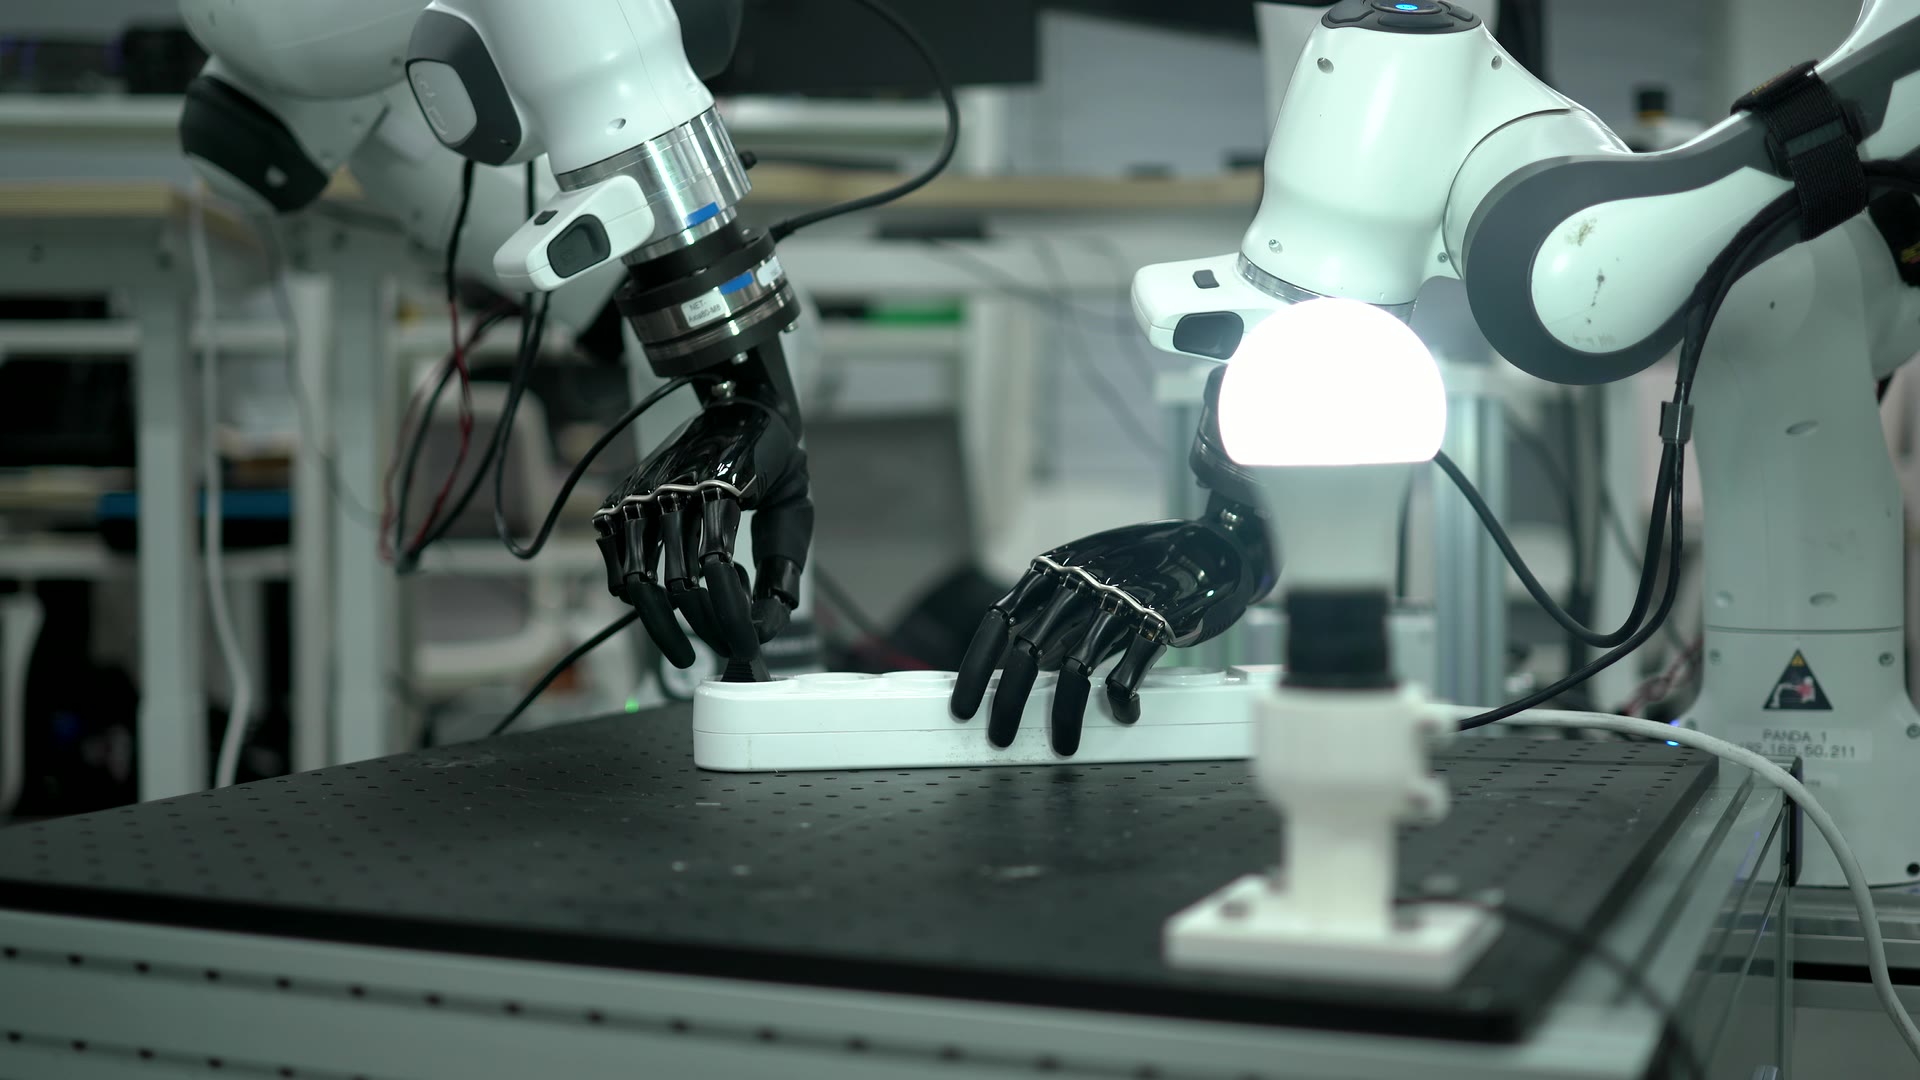
An arm that teaches by feel, a glove that records touch, a studio for capture and review, and Lucid for bilateral control.
Live demo available
Explore Dream CatcherNine layers per episode, from task video to wrist torque, recorded on one clock.
Available
Explore Dream Set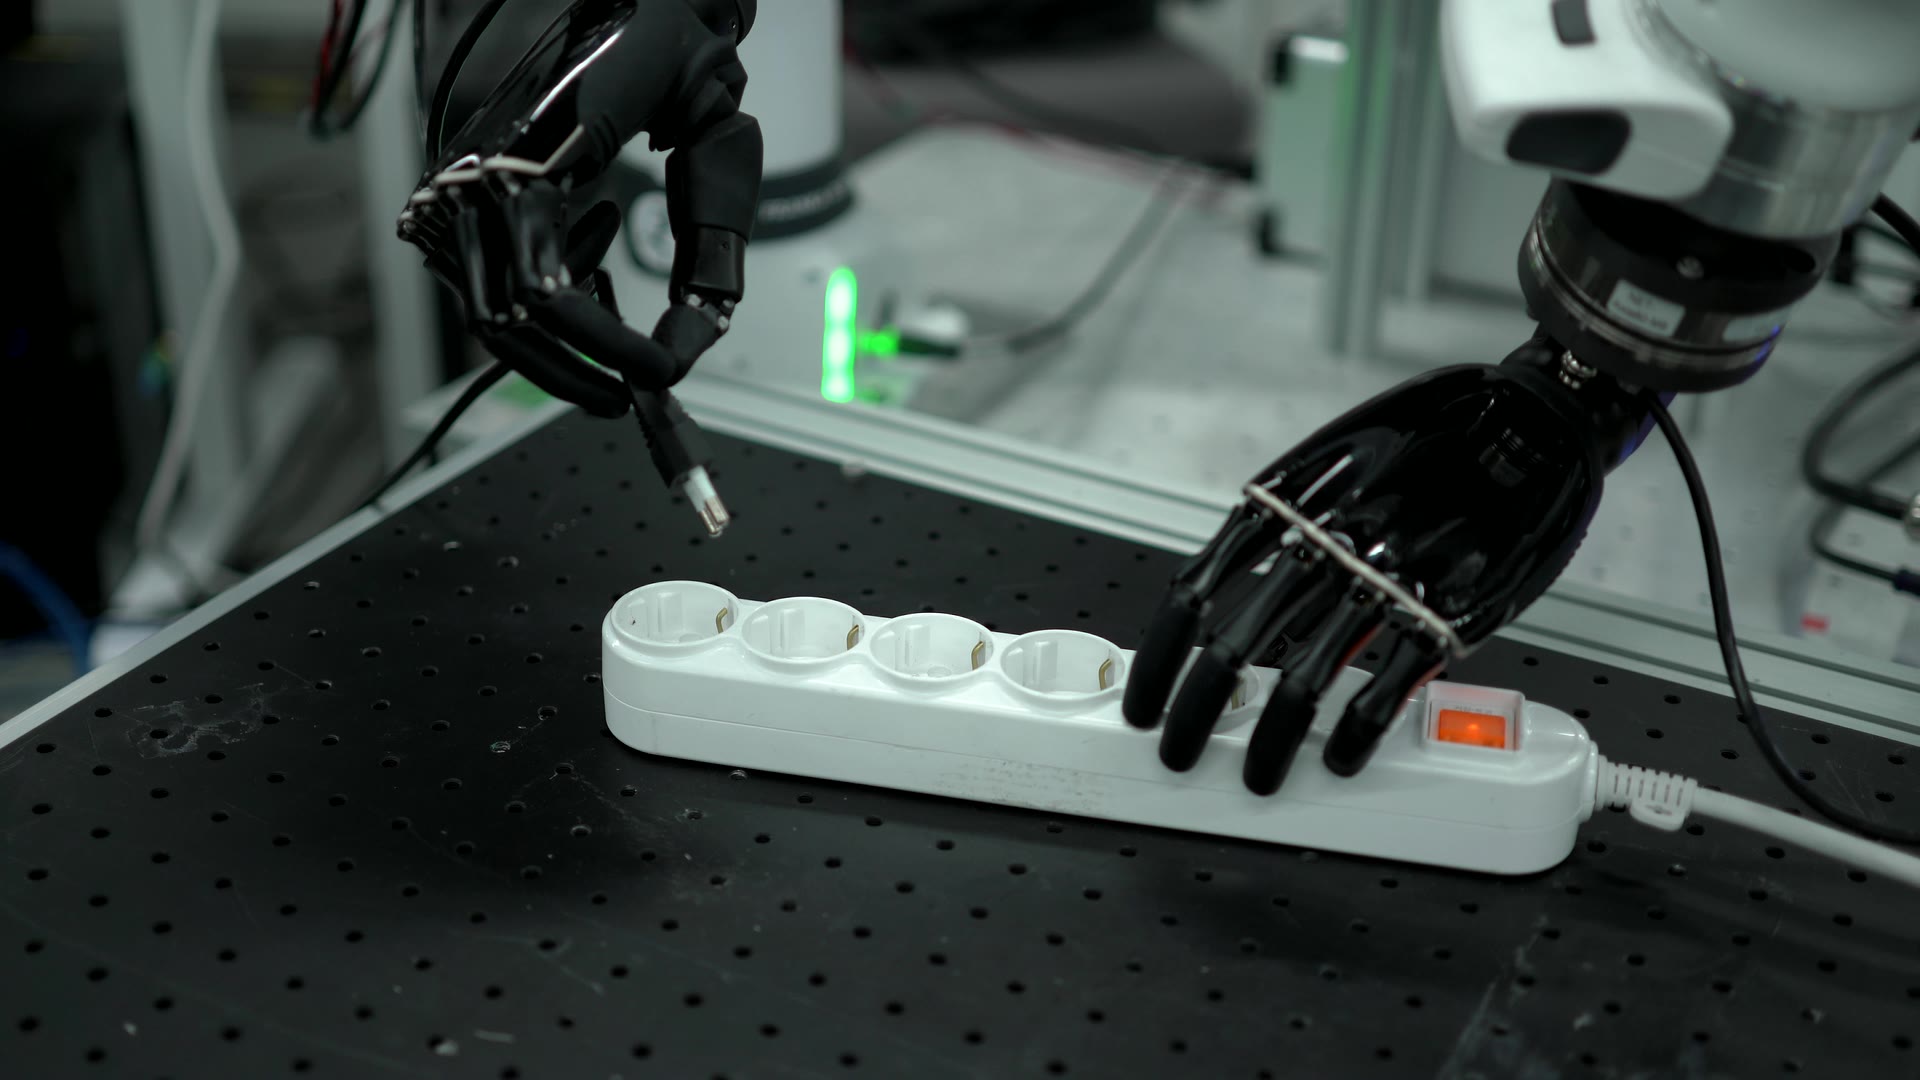
A contact intelligence foundation model, built on open backbones with a layer that understands force.
Coming soon
83%
Success when the policy learned force and torque. Video alone reached 22%.
ManipForce, 2025. Six tasks, averaged, rounded.
+23.2pp
Gain from adding force-aware fusion to π0, from 37.3% to 60.5%.
ForceVLA, 2025. π0 baseline, five tasks.
1.09s
To mate a moving HDMI socket. A person takes 1.04 s.
SHIELD, RSS 2021. Dedicated force and vision system.
Kinesthetic layers. Shapes are illustrative.
Sustained torque
Vibration load
Insertion peak
Shifting mass
Fine pressure
Electronics, automotive, shipbuilding, heavy industry.
We will answer with a demonstration.
Help teach robots the sense of touch.
See openings